Robot platform
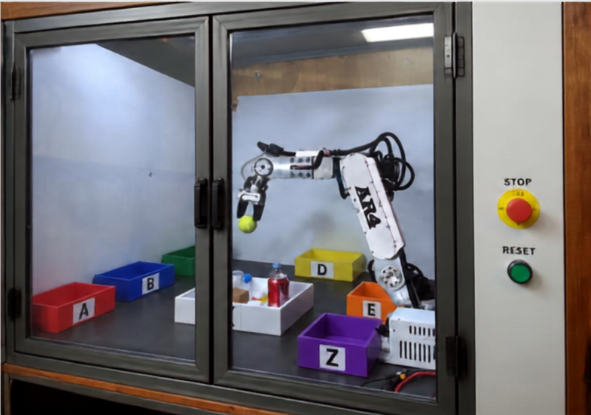
Build and study the AR4-MK5 arm, its motion hardware and cell layout.
Independent technical development lab · Sardinia
Exploring robotics, industrial automation, functional safety and AI vision through hands-on development.
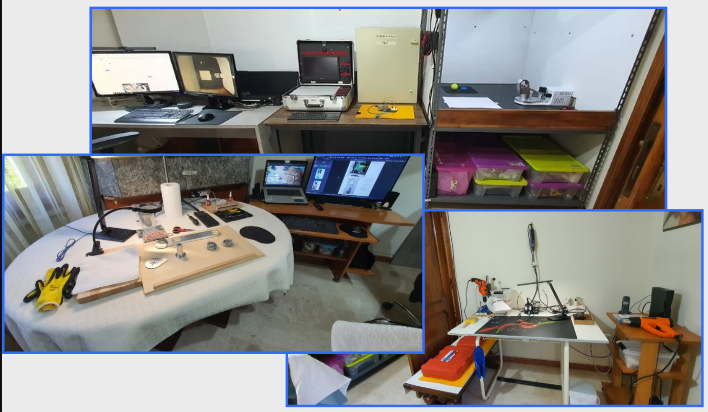
PaMiLoLAB is Paolo Gaggé’s independent personal technical development initiative, created in a non-commercial, open-source spirit to learn, experiment and share knowledge.
Its work brings mechanical engineering together with control systems, safety thinking and machine vision. Ideas move from drawings to hardware, then through testing, correction and documentation.
A hands-on robotic cell development platform for object recognition, handling and, ultimately, material sorting.
The platform starts with an AR4-MK5 six-axis robot and progressively brings together PLC automation, electrical and functional safety, cameras, depth sensing and AI vision. The proposed sorting task is a development goal; it has not been presented here as a validated capability.
Build and study the AR4-MK5 arm, its motion hardware and cell layout.
Develop interfaces between the robot, PLC, drives and operator controls.
Address electrical design, guarding, stop functions and validation as development proceeds.
Explore how image and depth information can guide recognition and manipulation.
PaMiLoLAB documents each step, including errors and changes, so that ideas can improve through evidence from the bench.
Turn a technical question into drawings and hardware.
Check the assembly, control chain and behaviour.
Identify what failed or changed and why.
Record the result and begin the next iteration.
Shared drawings, architectures and technical ideas represent ongoing development; they are not finished or certified engineering solutions.
Exchange knowledge
PaMiLoLAB welcomes exchange with engineers, technicians, makers, researchers and open-source communities working in robotics, automation, safety and AI vision.